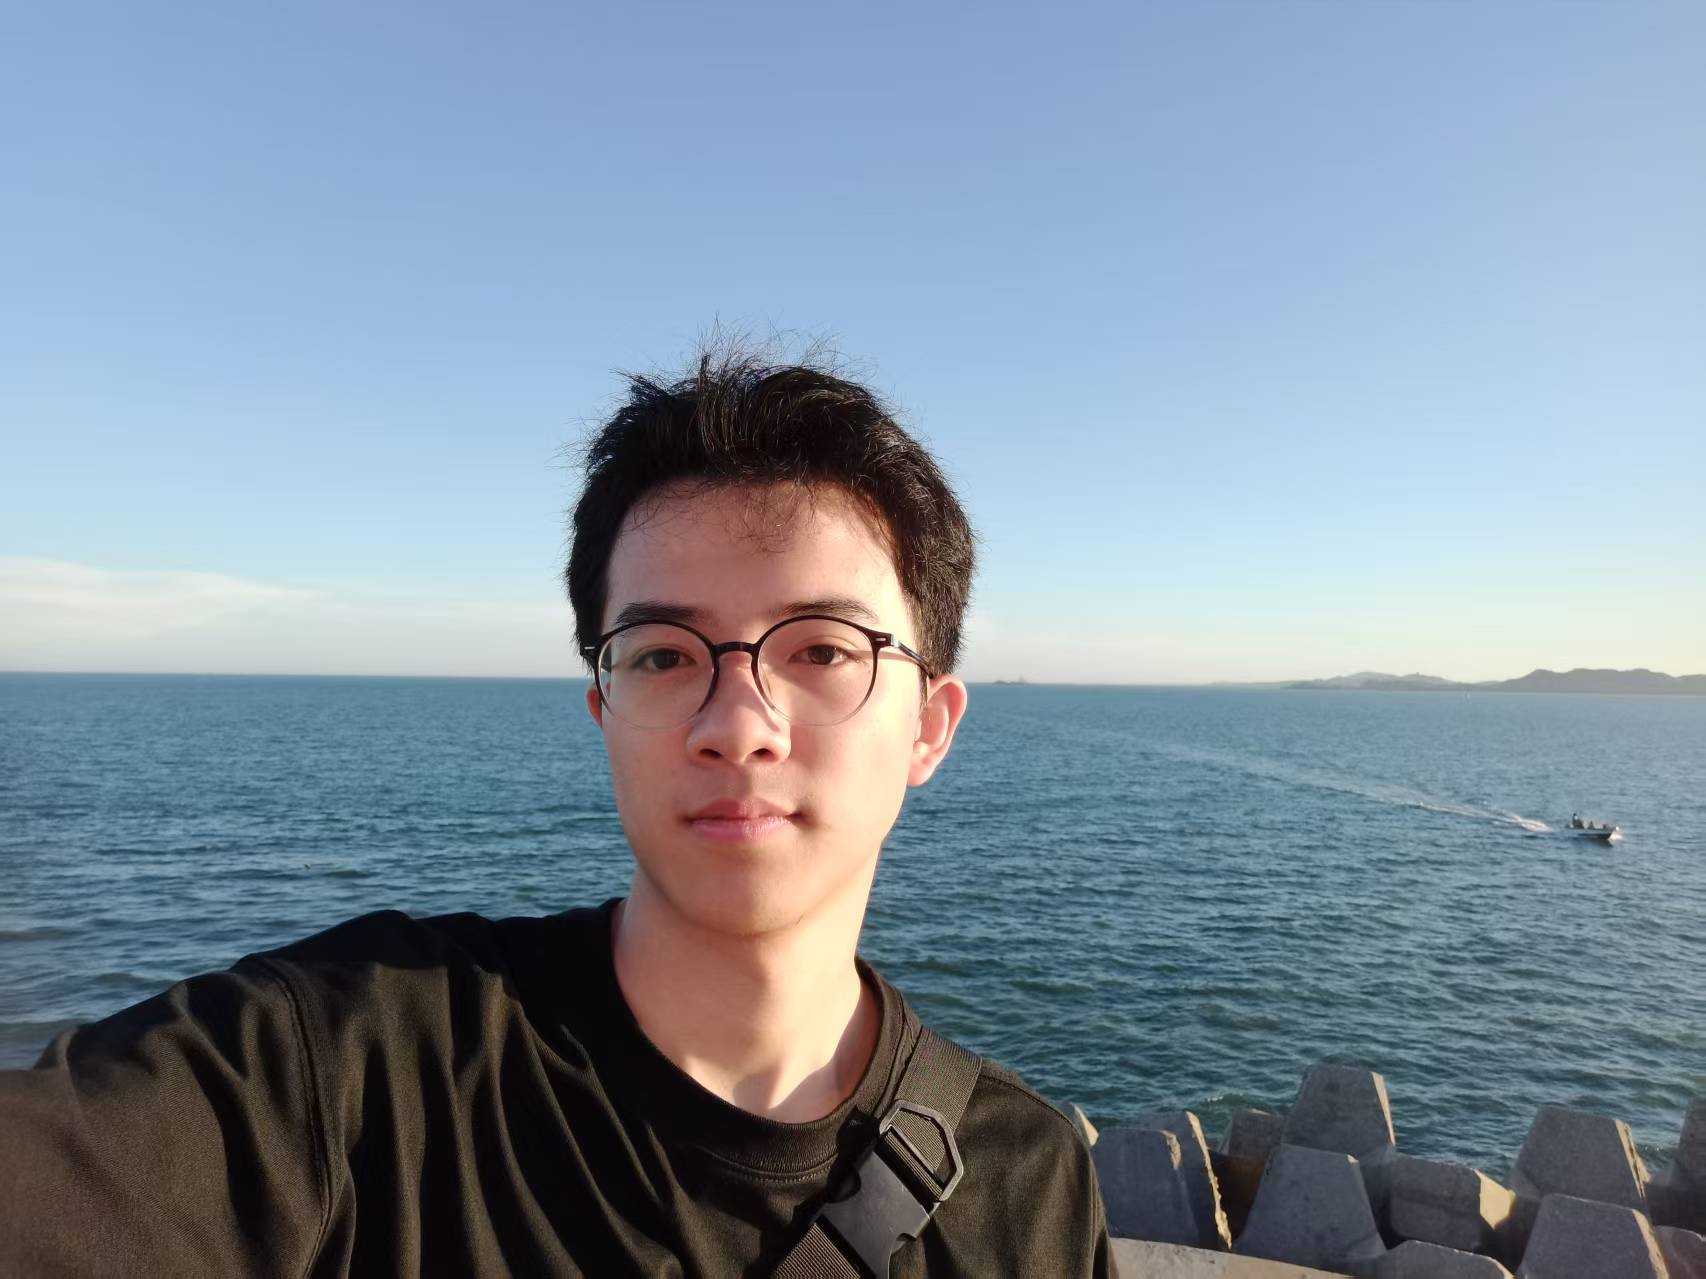

I am currently a master’s student in Transportation Engineering at Northeast Forestry University, advised by Huizhi Xu(徐慧智). My research focuses on vision-based traffic object detection and Bird’s-Eye-View(BEV) perception, especially roadside 3D object detection, BEV representation learning, and monocular distance and orientation estimation for intelligent transportation systems.
Besides academic research, I also write notes and reflections on graduate study, research practice, paper writing, and technical learning. I share some of these writings through my WeChat Official Account Douglas 交通 and CSDN.
📝 Publications
Xu Huizhi, Junjie Lai. BEVDistance: Monocular Vehicle Distance and Orientation Perception Based on Bird’s-Eye-View Features. Computer Engineering and Applications, 2026.
Junjie Lai, Huizhi Xu. BEV Bank:Scene-wise BEV Memory for Vision-based Roadside Object Detection. IEEE Sensors Journal, 2026.
Huizhi Xu, Junjie Lai, Yulong Chen, et al. ST-DeM: Enhancing DeepSORT with SwinTransformer and Attention-Augmented MobileNetV3 for Robust Illegal Parking Detection. In The Proceedings of 2025 International Conference on Artificial Intelligence and Autonomous Transportation, 2026.
Huizhi Xu, Xinying Tao, Junjie Lai, et al. Vehicle Tracking and Trajectory Extraction Based on Deep Learning. In Ninth International Conference on Traffic Engineering and Transportation System (ICTETS 2025), 2026.
📖 Educations
- Sep. 2024 – Present, M.S. in Transportation Engineering, Northeast Forestry University, Harbin.
- Sep. 2020 – Jun. 2024, B.S. in Traffic Engineering, East China Jiaotong University, Nanchang.
- Sep. 2017 – Jun. 2020, Guangchang No. 1 High School, Fuzhou.